Robotics / Perception / Autonomy
Haoyu Shen
I am a Ph.D. student in Systems Engineering at Boston University, currently rotating in the Dependable Computing Lab with Prof. Wenchao Li. I work on decentralized multi-agent planning from temporal-logic specifications and am deploying it on AgileX LIMO ground robots in BU's RASTIC testbed. Before joining BU, I worked on robotic perception and autonomous navigation at CMU CERLAB and the ZJU FAST Lab, including LiDAR-visual dynamic obstacle detection and tracking and GPS-denied UAV autonomy.
Research Focus
LiDAR-visual obstacle detection, tracking, and scene understanding for autonomous robot navigation.
Planning, localization, and onboard perception for UAVs operating in GPS-denied and cluttered environments.
Reliable hardware and software integration for UAV, USV, and mobile robot platforms.
Selected Work

LV-DOT: LiDAR-Visual Dynamic Obstacle Detection and Tracking
Dynamic obstacle detection and tracking framework validated on UAV and Unitree Go2 platforms for autonomous navigation. Co-first author.
ASIP-Planner: Adaptive Planning for UAV Surface Inspection in Partially Known Indoor Environments
Adaptive UAV inspection framework for surface coverage in partially known indoor environments, where floorplan-derived reference maps may not reflect unforeseen obstacles. IEEE/RSJ IROS 2026. I developed and integrated the dynamic-obstacle perception front end.
NavRL: Learning Safe Flight in Dynamic Environments
Learning-based safe flight policy for UAV navigation in dynamic environments, published in IEEE Robotics and Automation Letters. I developed and integrated the dynamic-obstacle perception front end.
Intent Prediction-Driven Model Predictive Control for UAV Planning and Navigation in Dynamic Environments
UAV navigation framework that integrates perception, intent prediction, and planning for safe flight in dynamic environments, published in IEEE Robotics and Automation Letters. I developed and integrated the dynamic-obstacle perception front end.

Tunnel Inspection Demo
Winter 2024 CERLAB field demonstration in a full-scale tunnel at the Fukushima Robot Test Field, Japan. I was responsible for the dynamic obstacle avoidance parts.
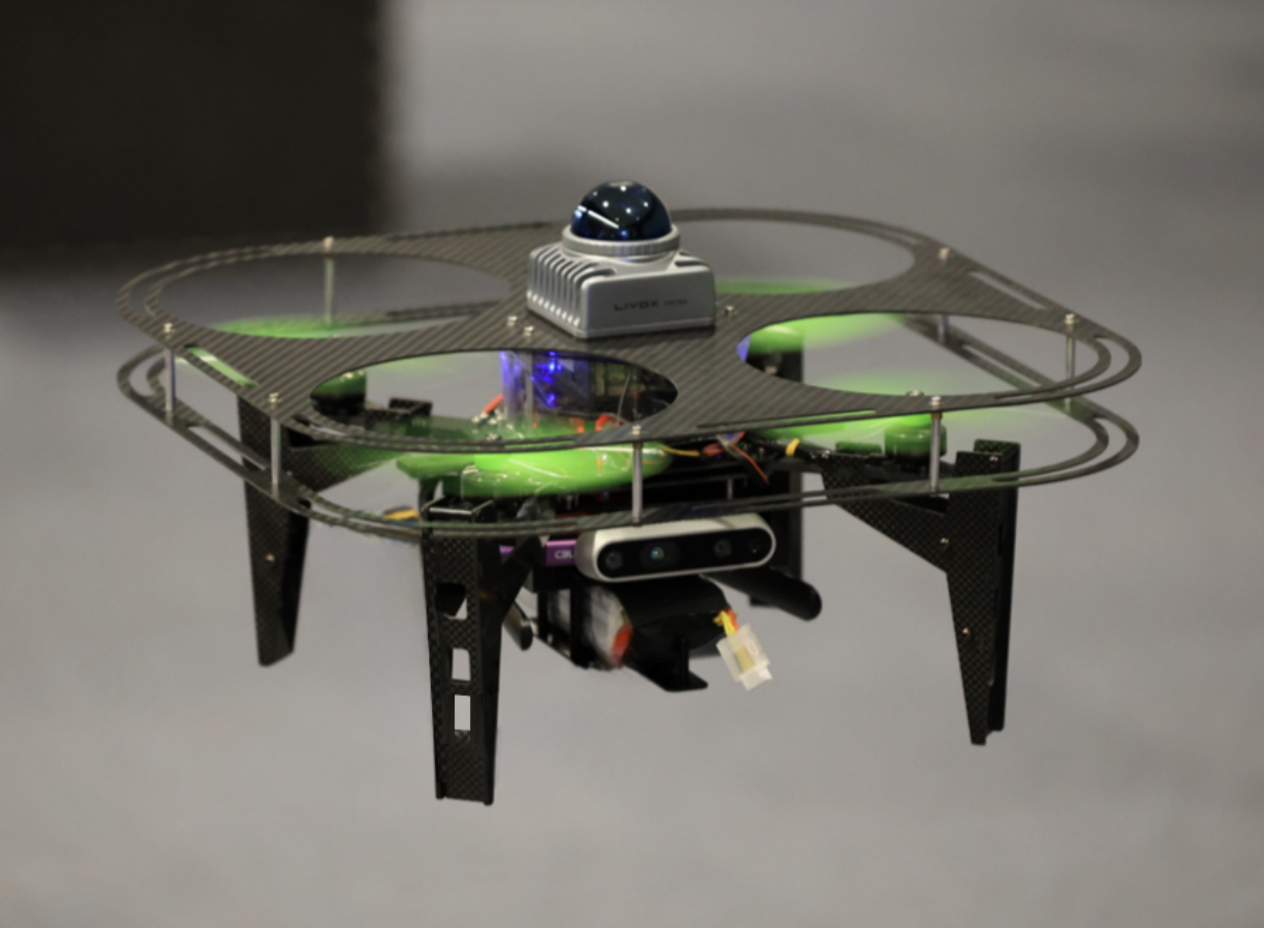
Lightweight Autonomous UAV
GPS-denied UAV platform integrating LiDAR localization, RGB-D sensing, onboard compute, and autonomous obstacle avoidance.

Unmanned Surface Vehicle
Undergraduate capstone: an independently designed dual-propeller, differential-driven surface vehicle platform based on ROS 2 Humble.
Experience
Boston University | Dependable Computing Lab
Boston, MA. Decentralized multi-agent planning from temporal-logic specifications, deployed on a fleet of AgileX LIMO ground robots in the BU RASTIC testbed.
Zhejiang University | FAST Lab
Hangzhou, China. Developed decentralized coordination algorithms for drone swarms to maintain robust flight and formation in communication-denied and GPS-denied environments.
CMU CERLAB | UAV Group
Pittsburgh, PA. Developed the LV-DOT LiDAR-visual perception framework (co-first author) and integrated the dynamic-obstacle perception front end for the lab's navigation systems (NavRL, Intent-MPC, ASIP-Planner).
News
2026
- ASIP-Planner accepted to IEEE/RSJ IROS 2026.
- AugStarted as a Ph.D. student in Systems Engineering at Boston University.
2025
- NavRL published in IEEE Robotics and Automation Letters.
- Intent Prediction-Driven MPC published in IEEE Robotics and Automation Letters.
- LV-DOT preprint released for LiDAR-visual dynamic obstacle detection and tracking.
Contact
Email: haoyus@bu.edu
Last updated: 10/2026