Portfolio
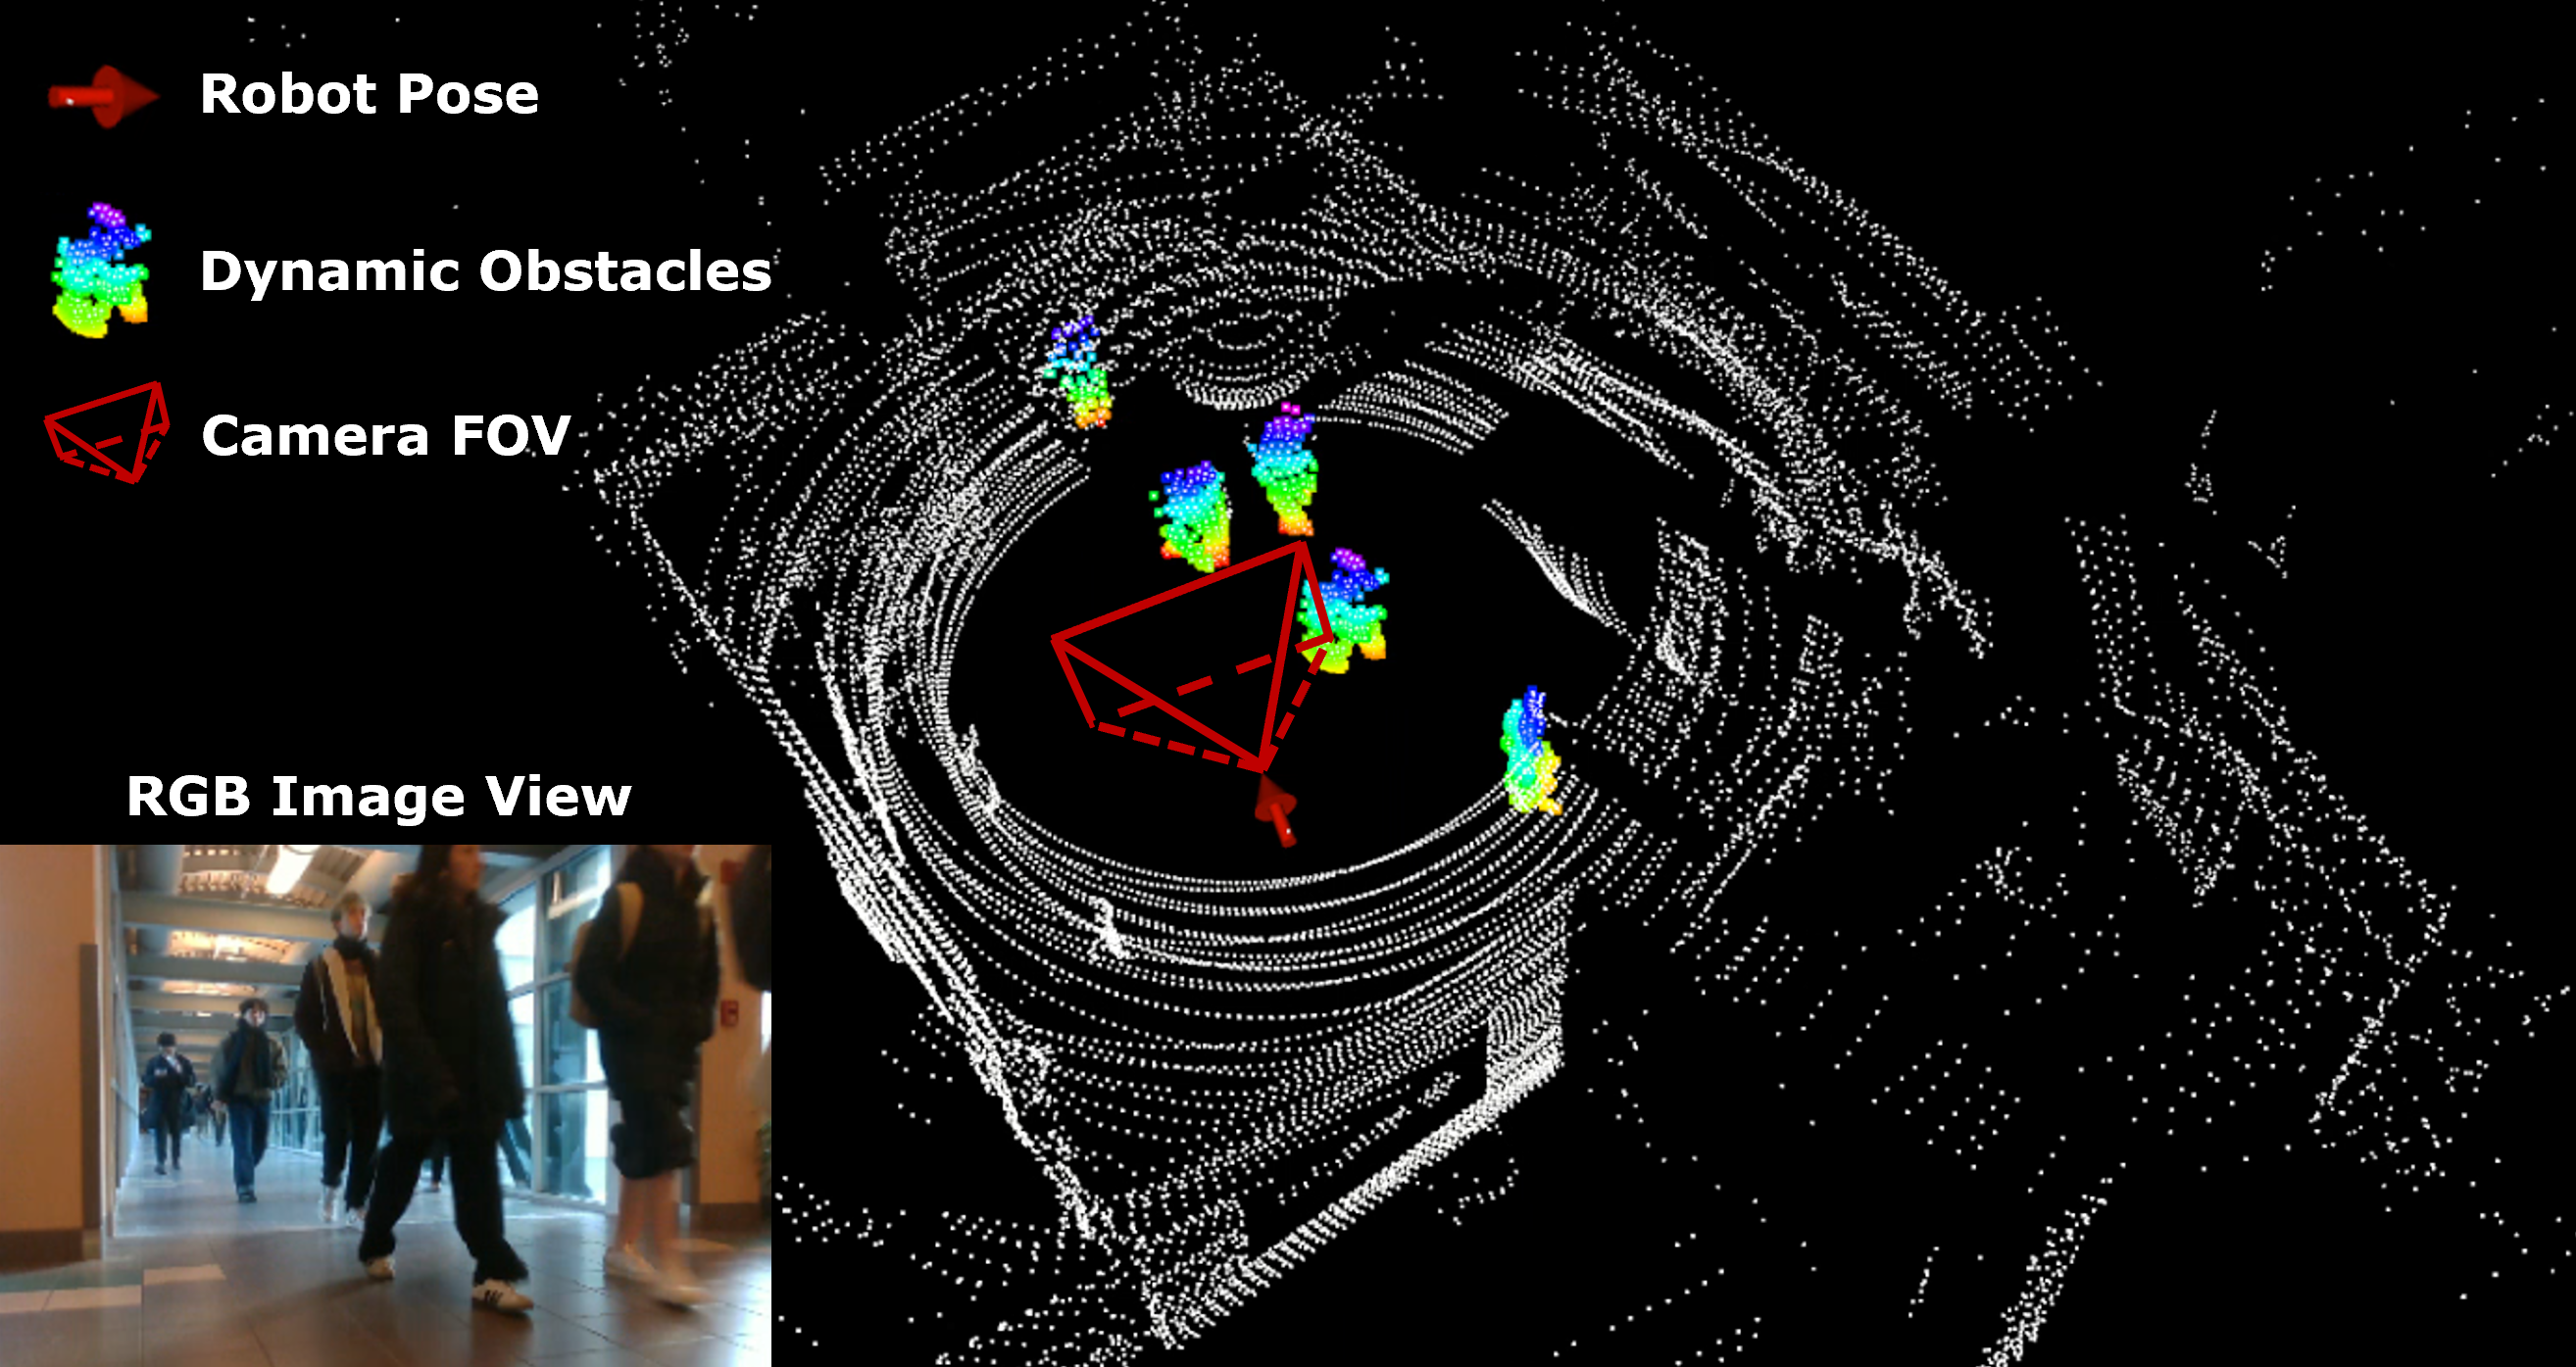
Dynamic Obstacle Detection and Tracking
LiDAR-visual dynamic obstacle detection and tracking that fuses DBSCAN 3D clustering with YOLO semantics and a Kalman filter, validated on both UAV and Unitree Go2 platforms.
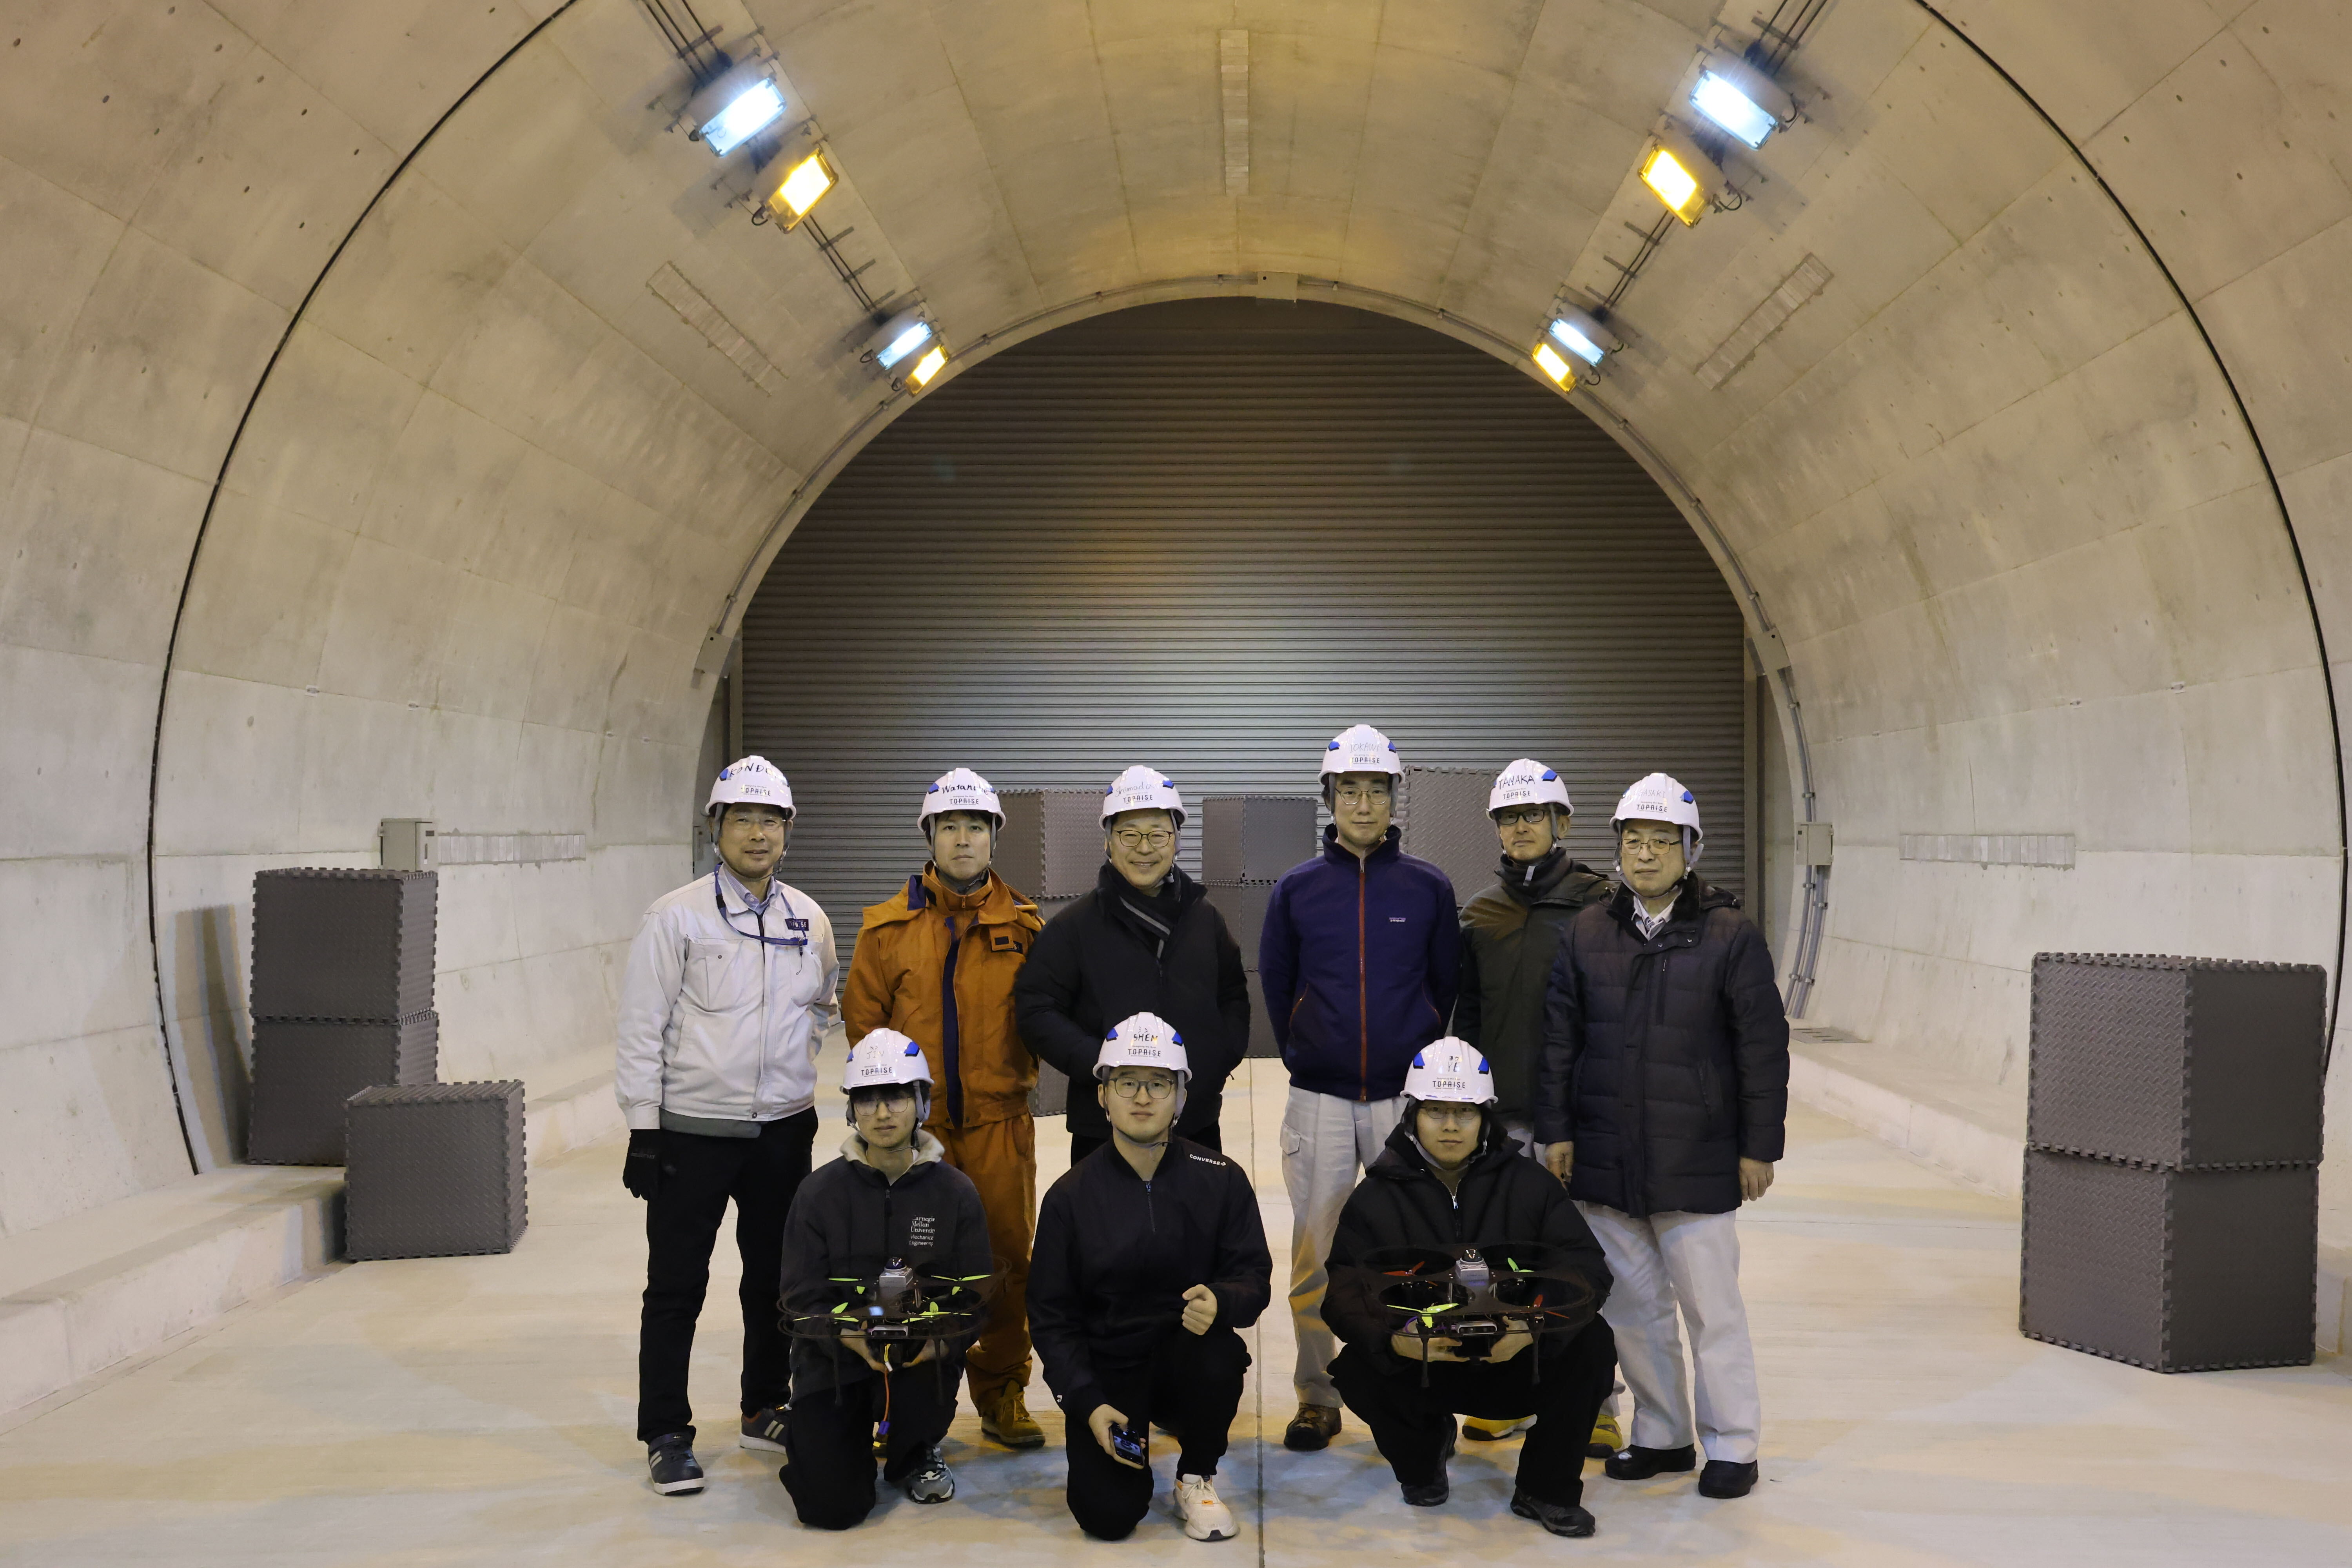
Tunnel Inspection Demo (Fukushima, December 2024)
Winter 2024 CERLAB field demonstration in a full-scale tunnel at the Fukushima Robot Test Field, Japan. I was responsible for the dynamic obstacle avoidance parts, using a LiDAR UAV with LIO positioning and real-time dynamic obstacle detection and tracking.
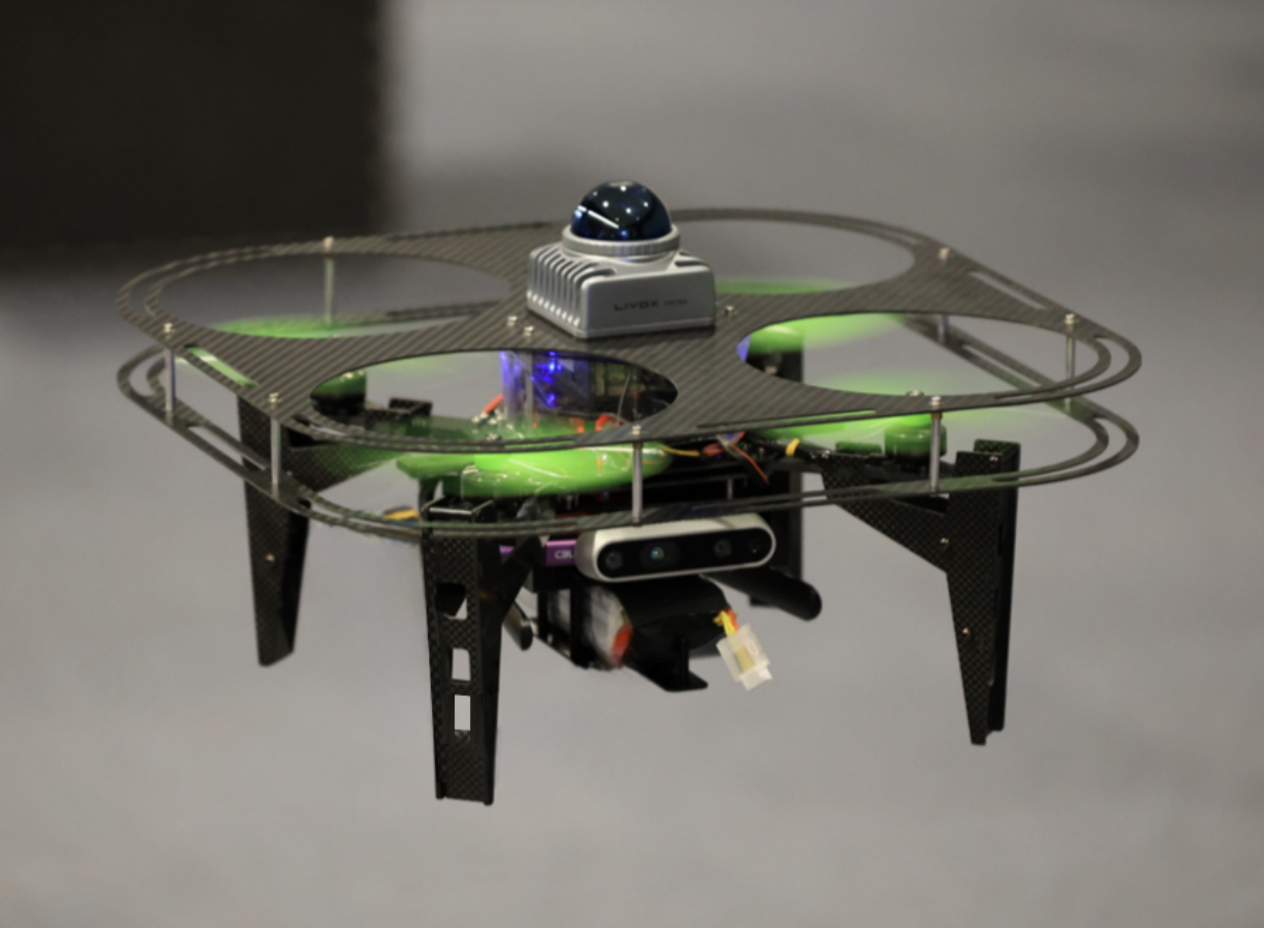
Light-Weight Autonomous UAV for Obstacle Avoidance
A lightweight UAV carrying LiDAR and an Intel RealSense D435i that navigates fully autonomously without GPS, using FAST-LIO2 fused with the PX4 IMU for high-rate odometry.

Unmanned Surface Vehicle
A full-stack autonomous surface vehicle built on a PX4 controller and ROS 2 Humble, navigating from GNSS and LiDAR perception — designed, manufactured, and assembled end to end.
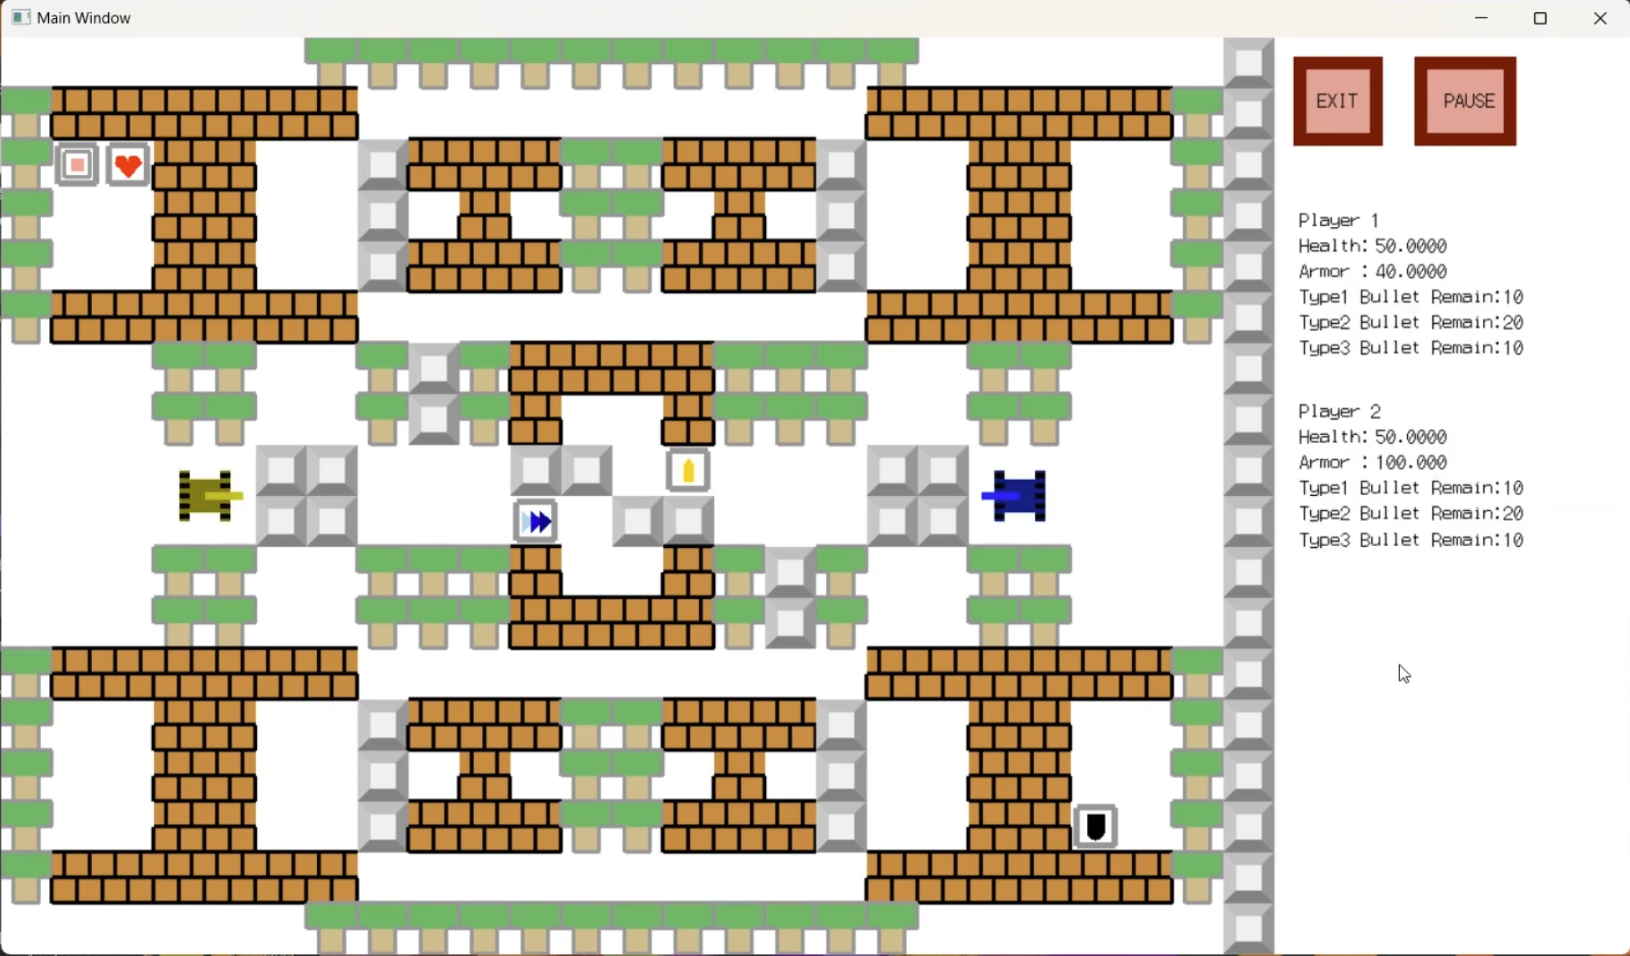
Battlecity Remastered (CMU 24-780)
A multiplayer C++/OpenGL remake of Battle City with several tank types and customizable maps, built to deepen the original’s tactical and cooperative play.